A member hinge limits the internal forces that are transferred from one member to other members. Hinges can only be arranged at the member ends, not at locations along the member.
Some member types already have hinges: a truss member, for example, transfers no moments, and a cable member transfers neither moments nor shear forces. You cannot assign hinges to such member types. The input is locked.
Basic
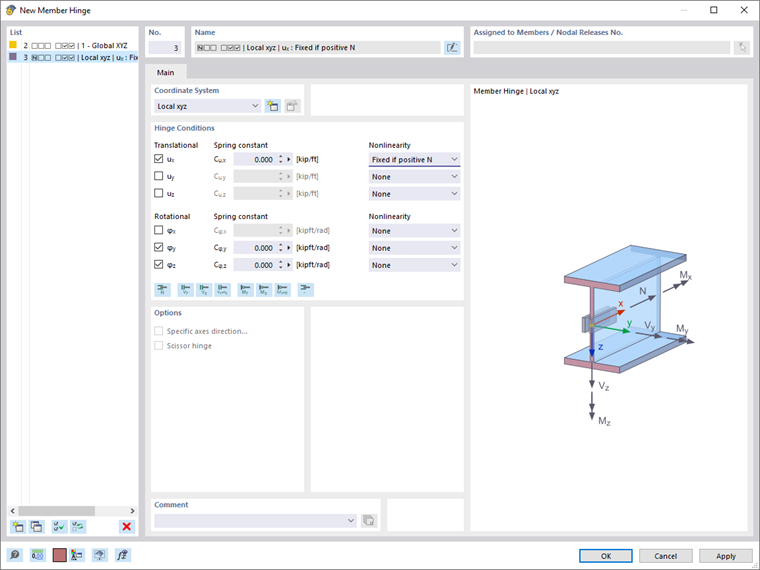
The Basic tab manages elementary hinge parameters.
Coordinate System
A member hinge can be related to one of the following axis systems:
- Local member axis system x,y,z
- Global coordinate system X,Y,Z (optionally as a scissor hinge)
- User-defined axis system U,V,W
As a rule, the hinges are related to the local member axis system. However, scissor hinges (see image member crossing) are only possible in the global or a user-defined axis system.
Hinge Conditions
The hinge conditions are divided into 'Translational' and 'Rotational' degrees of freedom. The former describe the displacements in the direction of the local or global axes, the latter the rotations about these axes.
To define a hinge, tick the check box for the respective axis. The check mark symbolizes that the displacement or rotation of the member in or about the corresponding direction is possible. The constant of the translational or rotational spring is then set to zero. You can adjust the 'spring constant' at any time to model an elastic hinge. Enter the spring stiffnesses as design values.
In the Nonlinearity column, you can specifically control the transfer of the internal forces for each component. Depending on the degree of freedom, suitable entries are available for selection in the list of nonlinearities.
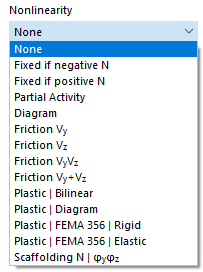
Rigid if Internal Force Negative or Positive
This allows you to easily control whether only positive or negative forces or moments are transferred at the member end. A ux hinge with the nonlinearity 'Rigid if N positive', for example, means that tensile forces (positive) are transferred at the member end, but no compressive forces (negative). For negative axial forces, a hinge is thus effective.
For a local coordinate system, the internal forces are related to the local xyz member axis system.
If you select another nonlinearity, you can define the parameters in the partial activity, diagram, friction, or scaffolding diagram tabs.
Options
The 'scissor hinge' is available in the global or user-defined coordinate system. It allows you to model the crossing of continuous members.
Example
Four members meet at a node. The members transfer moments in their "run-through direction", but not to the other pair of members. Only axial and shear forces are transferred in the node.
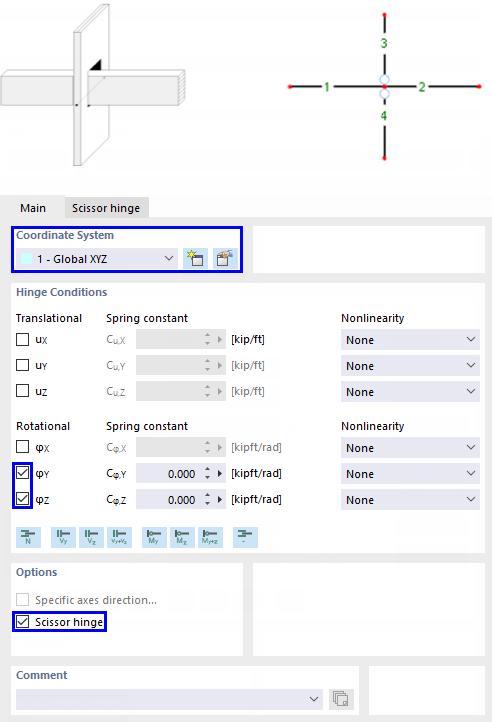
Assign the hinge either to members 3 and 4 or to members 1 and 2. The other crossing pair of members does not receive a hinge.
Partial Activity
The partial activity of a hinge component is available as a nonlinear property of the member hinge (see image selecting hinge nonlinearity).
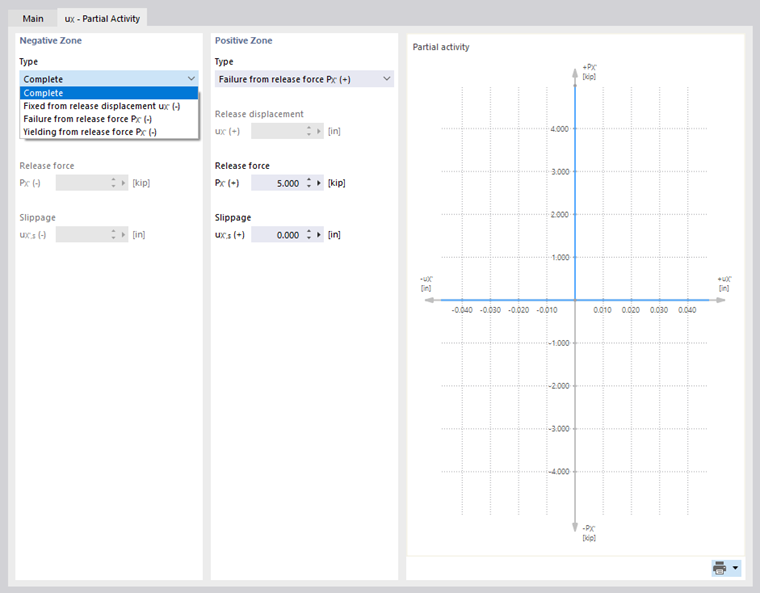
Define the effect of the hinge for the 'negative range' as well as for the 'positive range'. In the 'type' list, various criteria for the effectiveness of the hinge are available for selection.
- Complete: The displacement or rotation is fully possible through the hinge.
- Rigid from release displacement/release rotation: The hinge is only effective up to a certain displacement or rotation. If this is exceeded, a rigid connection or restraint becomes effective.
- Cracking from release force/release moment: The hinge is only effective up to a certain force or moment. If this is exceeded, the hinge fails and no longer transfers the internal force.
- Yielding from release force/release moment: The hinge is only effective up to a certain force or moment. If this is exceeded, the strains increase, but the internal force no longer does.
- Spring failure: For a hinge with spring stiffness, the component of the hinge is not effective.
Most hinge types can be combined with a 'slippage', which means that the hinge only becomes effective after a certain displacement or rotation.
Diagram
The diagram of a hinge component is available as a nonlinear property of the hinge (see image selecting hinge nonlinearity).
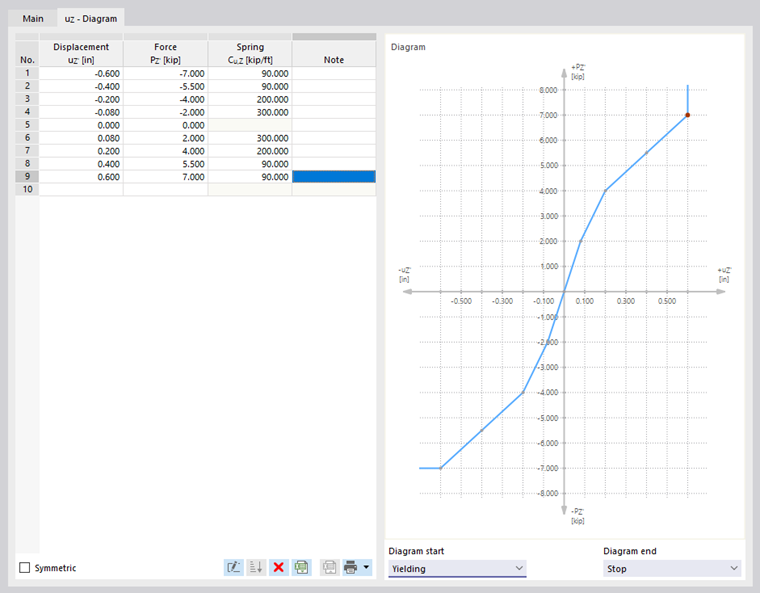
In the 'displacement' or 'rotation' column, define the number of definition points of the working diagram with the corresponding values. In the 'force' or 'moment' column, you can then assign the abscissa values of the displacements or rotations to the hinge forces or moments.
If the order of the definition points is not correct, you can sort the entries in ascending order using button
 .
The following criteria are available for the 'diagram start' and 'diagram end':
- Cracking: The hinge is only effective up to the maximum value of the force or moment. If this is exceeded, the full hinge effect occurs. No more internal force is transferred.
- Yielding: The hinge is only effective up to the maximum value of the force or moment. If this is exceeded, the strains increase, but not the internal forces.
- Continuous: Beyond the definition range, the spring constant of the last step is applied.
- Stop: The permissible deformation is limited to the maximum value of the displacement or rotation. If this is exceeded, the hinge effect is canceled and a rigid connection or restraint becomes effective.
Friction
In the 'nonlinearity' list, four options are available for defining the friction of a translational hinge depending on another hinge component (see image selecting hinge nonlinearity).
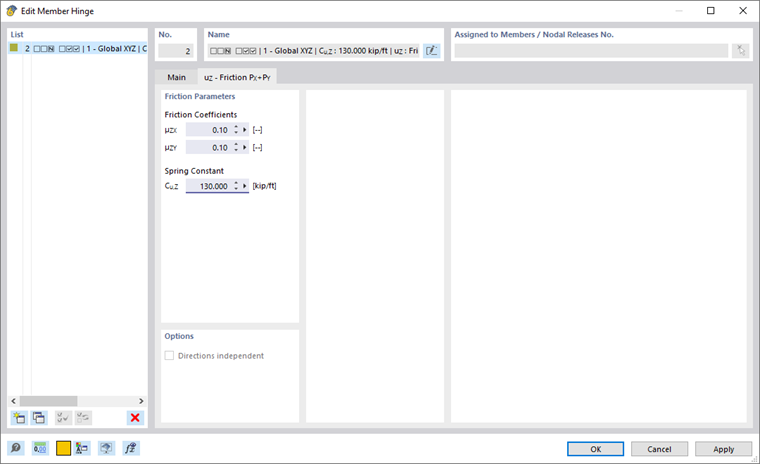
The transferred hinge forces are related to the axial or shear forces acting in another direction. Depending on the selection in the 'basic' tab, the friction depends on one or two internal forces. The following relationship exists between the hinge friction force and the axial force or shear force:
Plastic
Plastic hinge properties are important for pushover analyses. For the plastic option of a nonlinearly acting hinge component, four options are available (see image selecting hinge nonlinearity):
- Bilinear
- Diagram
- FEMA 356 | Rigid
- FEMA 356 | Elastic
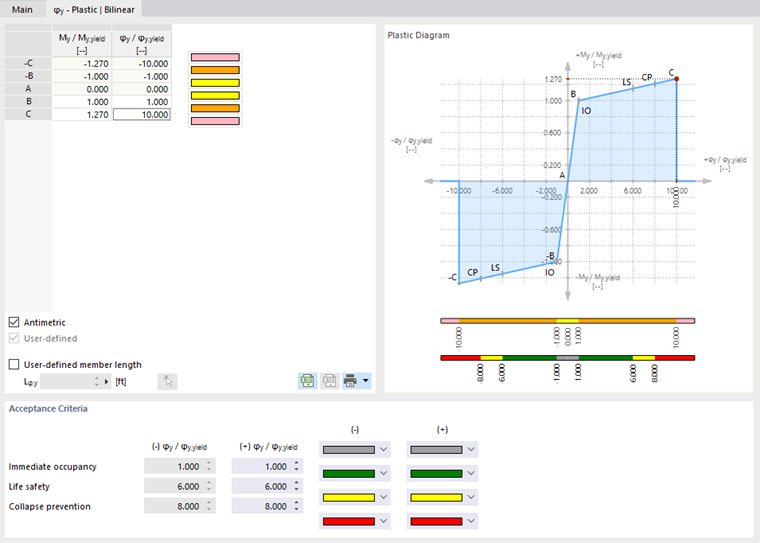
In the columns '"internal force" / "internal force"yield' and 'δ / δyield' or 'φ / φyield', define the characteristic values of the plastic ranges. For a value of My / My,yield of, for example, 1.27, the cross-section begins to yield as soon as the plastic moment is exceeded. If 127% of the plastic load capacity is exceeded, the member fails.
The plastic limit internal forces are automatically determined from the cross-section properties of the member.
The member length affects the stiffness calculation of the plastic hinge. As a rule, it is automatically recognized from the lengths of the members to which the hinge is assigned. If necessary, you can specify a 'user-defined member length' for the hinge.
Acceptance Criteria
In the lower section, you can define the limit values of the yield criteria that are to apply to the safety of the building. For steel components, these are regulated, for example, in Table 5-5 of the ASCE standard FEMA 356 [1]. Thus, for a value of φ / φyield of 6.000, the critical value for 'life safety' is reached as soon as the plastic deformations become six times larger than those occurring when the yield strength is reached.
The ranges of the acceptance criteria are also shown in the diagram.
For one of the two plastic FEMA options, the acceptance criteria are preset according to the specifications of the US standard. You can adjust them if necessary by ticking the 'user-defined' check box.
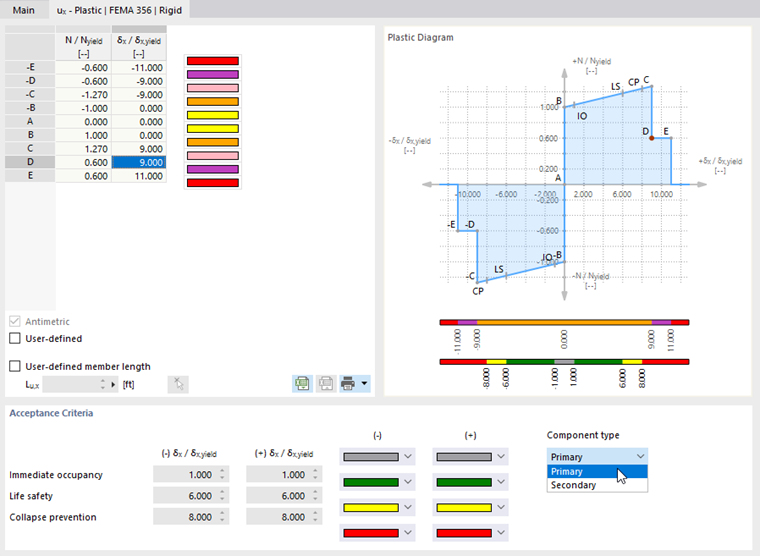
In the list, define the 'component type'. The acceptance criteria for primary and secondary components are regulated in [1] Table 5-5.
The technical article plastic hinges in RFEM 6 describes how to use a plastic hinge for a pushover analysis.
Scaffolding Diagram
The scaffolding diagram of a hinge component is available as a nonlinear property of the hinge (see image selecting hinge nonlinearity). It allows you to model the mechanical effect of a plugged pipe connection with an inner pipe stub between two members. The equivalent model transfers the bending moment – depending on the compression state at the member end – via the pressed outer pipe and, due to form fit, additionally via the inner pipe stub.
You can describe the hinge properties separately in the 'scaffolding diagram | inner tube' and 'scaffolding diagram | outer tube' tabs.
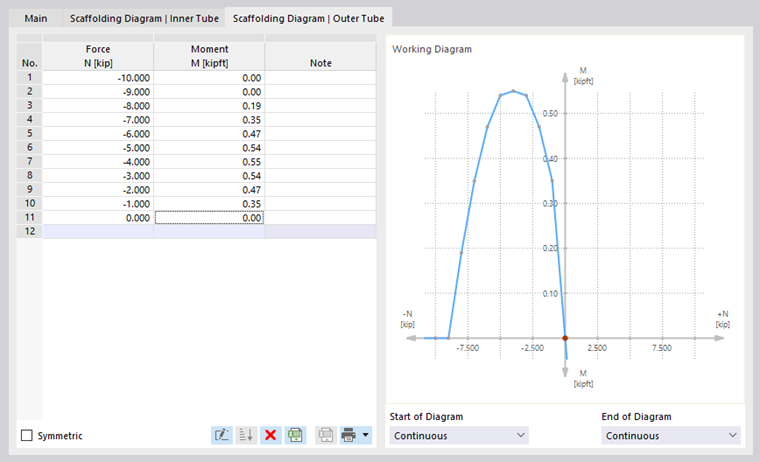
The options presented in the diagram section are available for defining the parameters.